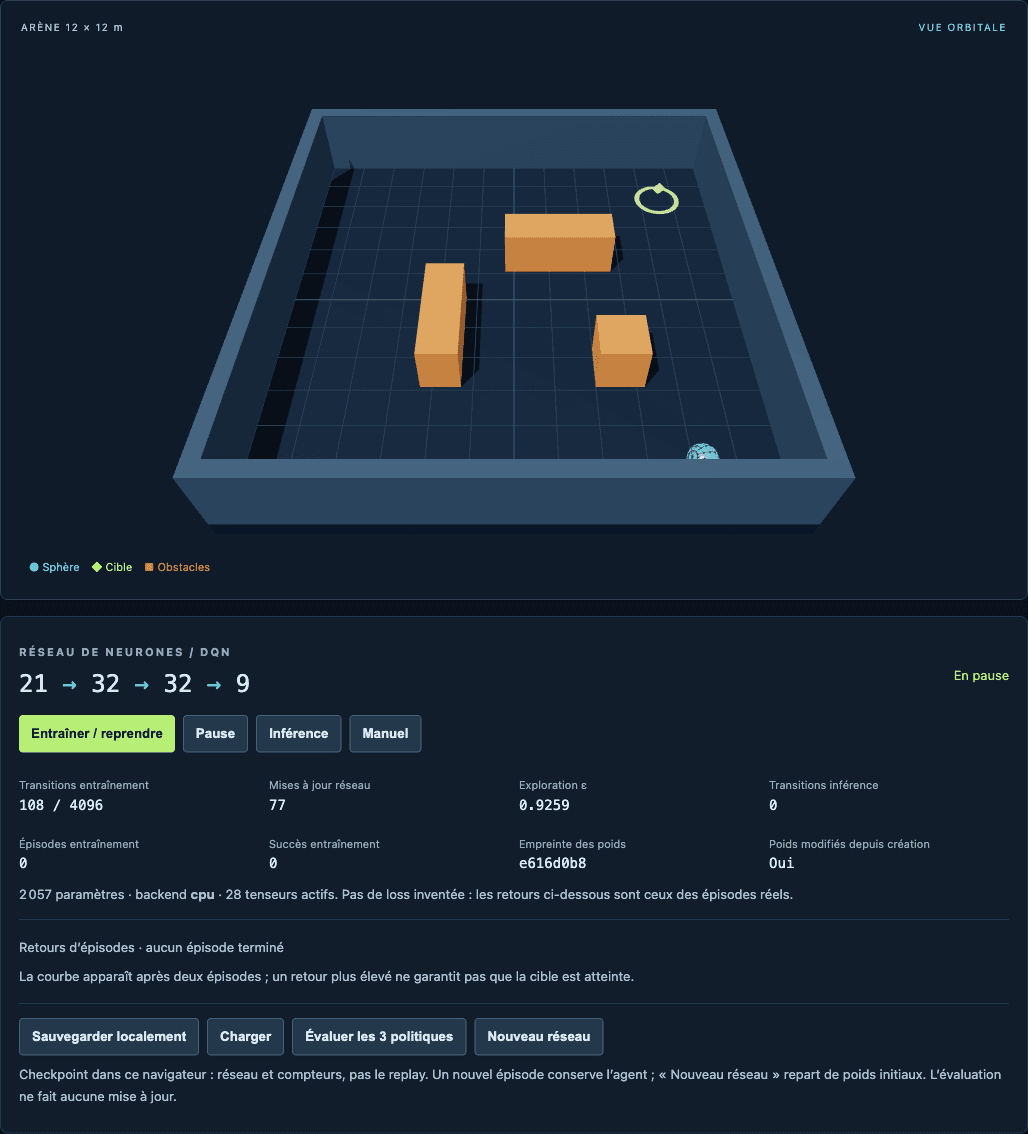
Ball Thrust 3D: from Rapier to a trainable DQN
Real physics, 21 observations, a DQN that learns and verifiable inference after a local checkpoint reload.
Read the tutorial →
The Ignition blog
Reproducible experiments, code, and agents in action.
Real physics, 21 observations, a DQN that learns and verifiable inference after a local checkpoint reload.
Read the tutorial →
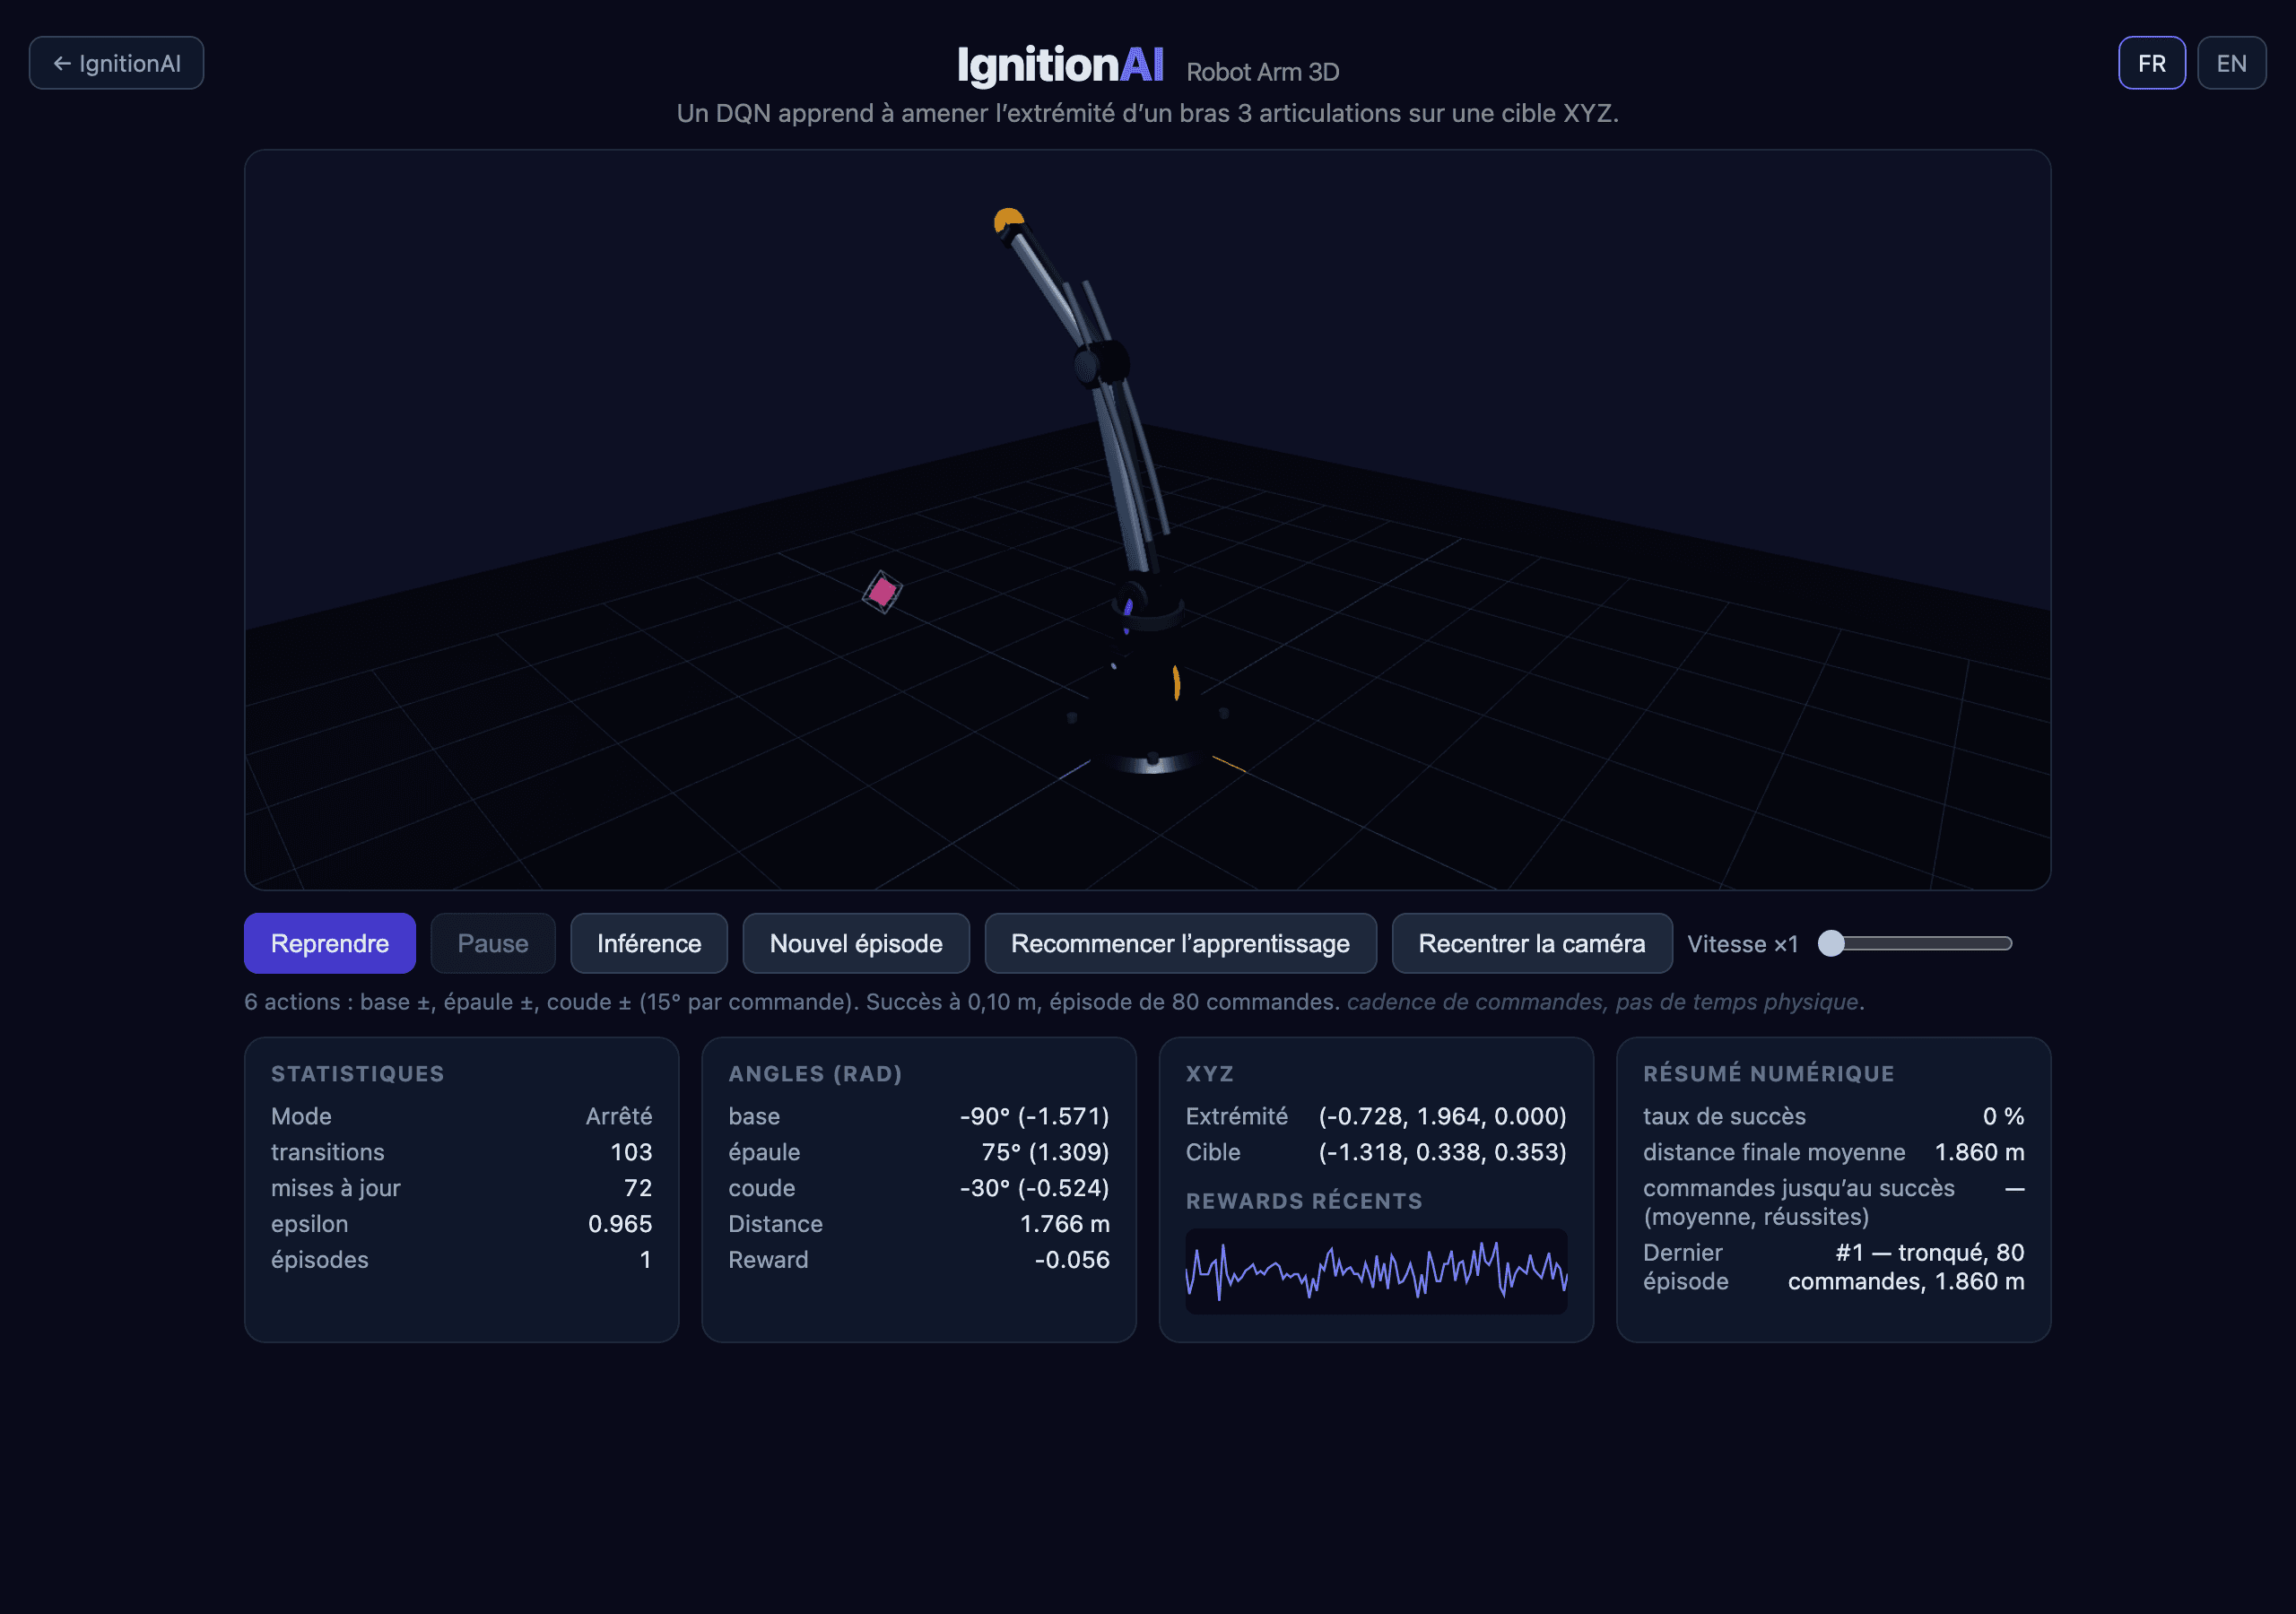
An ideal 3-joint arm, 325 configurations and 6 actions: follow how a dense reward brings the tip closer to the target, with real measurements and their limits.
Read the tutorial →
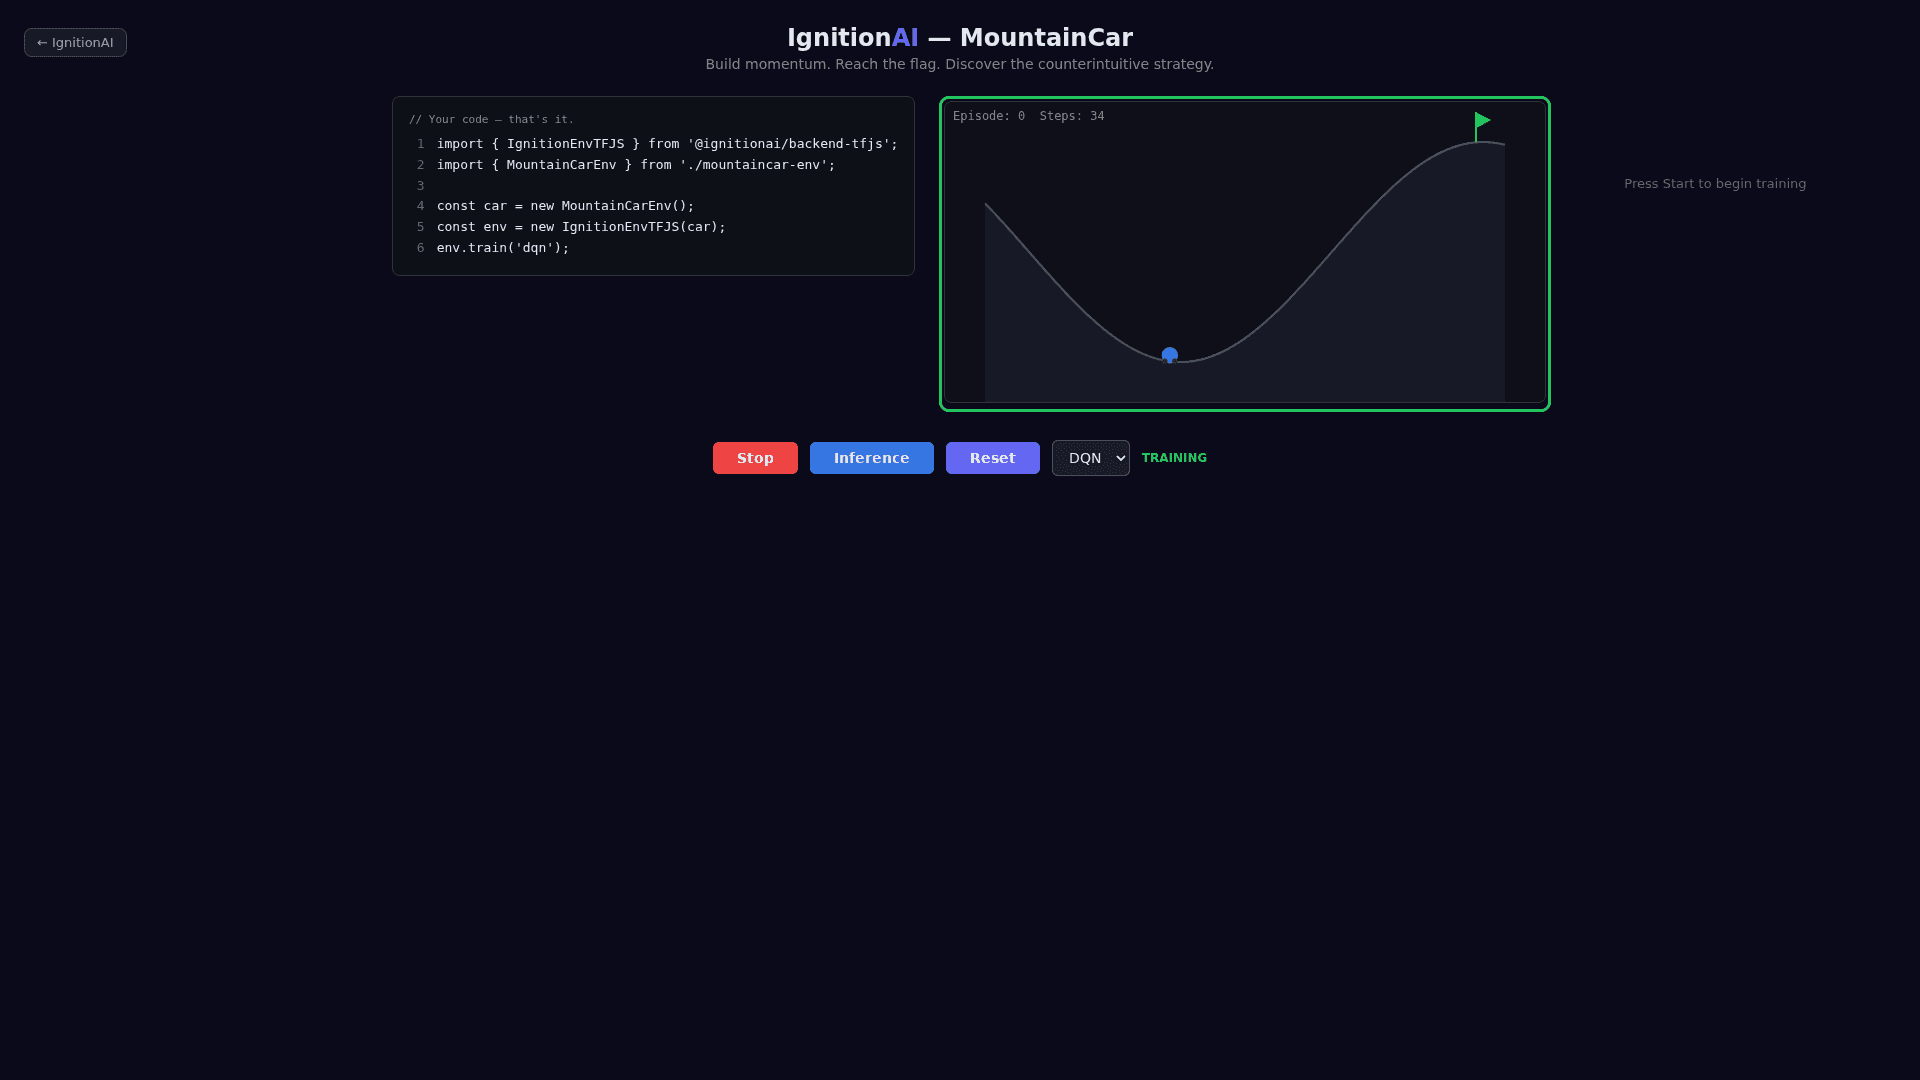
Understand why backing up can help an agent reach the summit.
Read the tutorial →
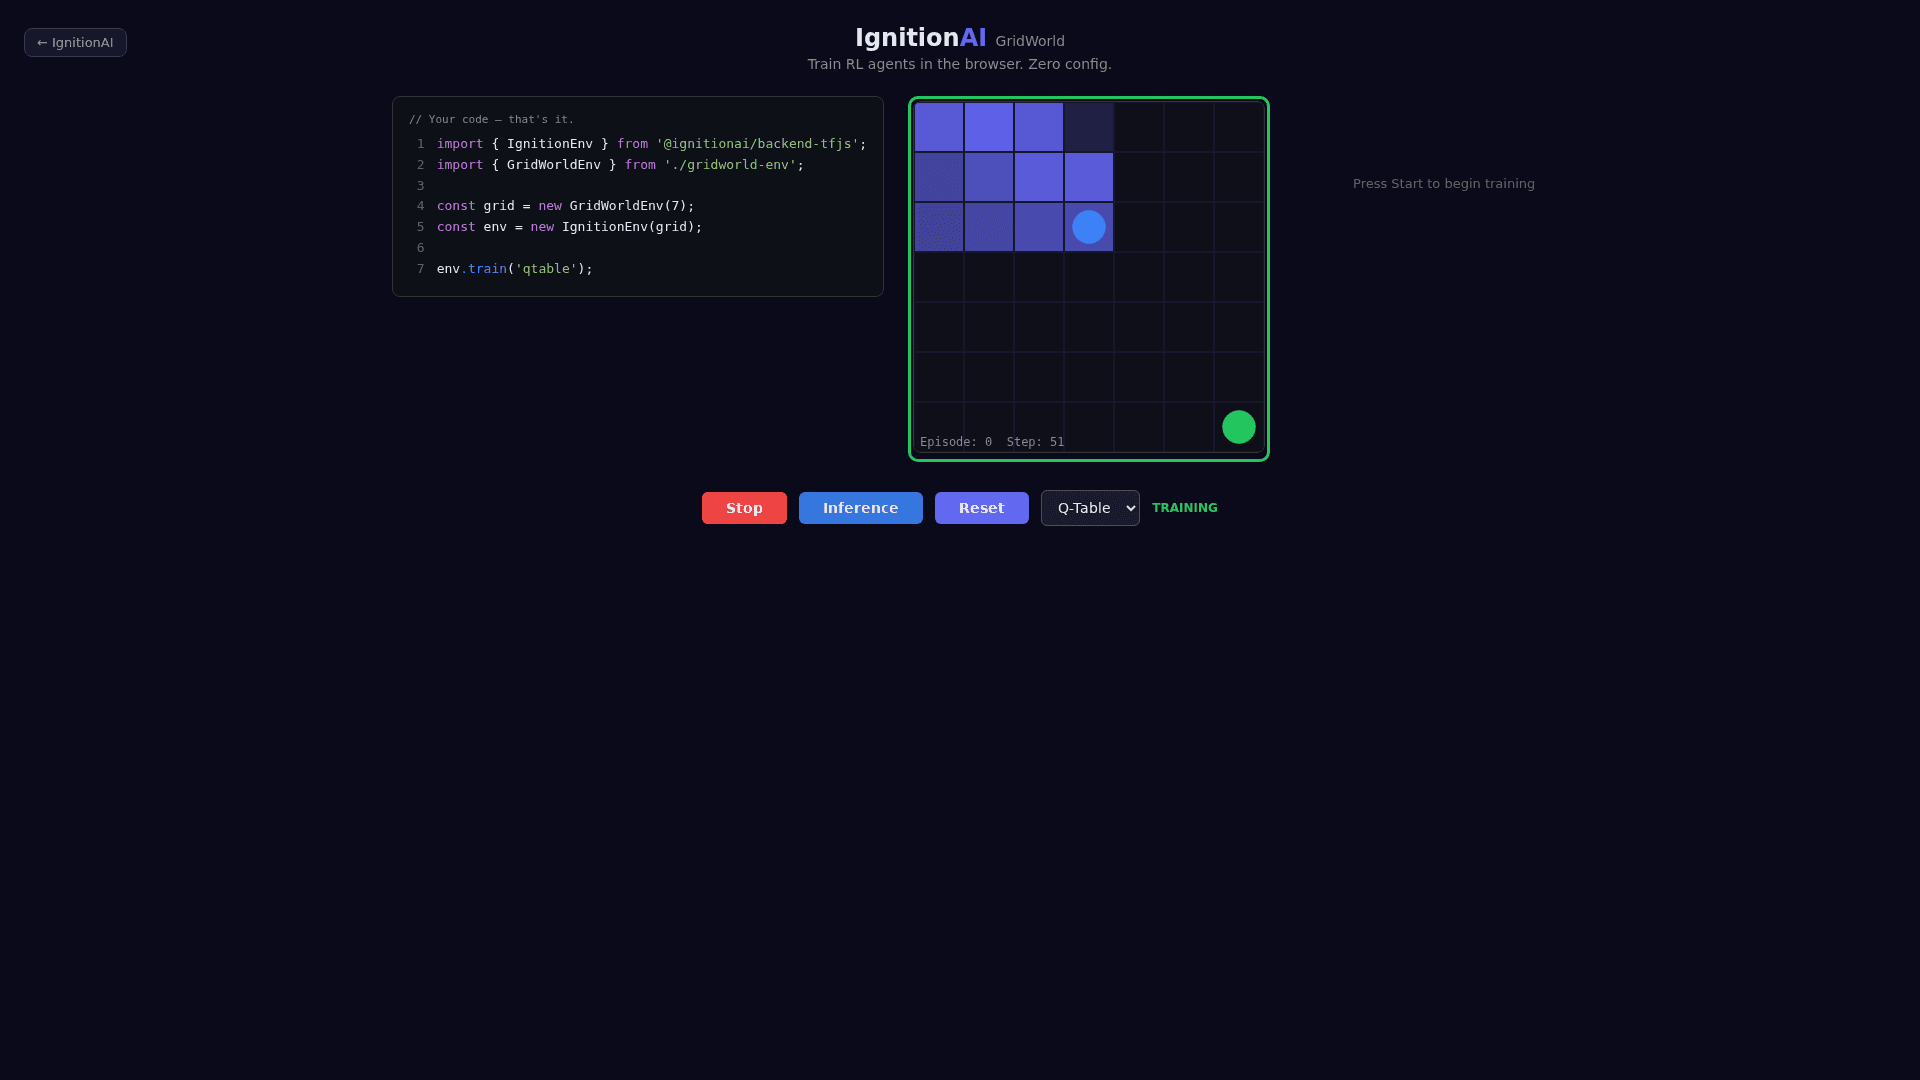
Visualising Q-values on a grid to understand what the agent learned.
Read the tutorial →
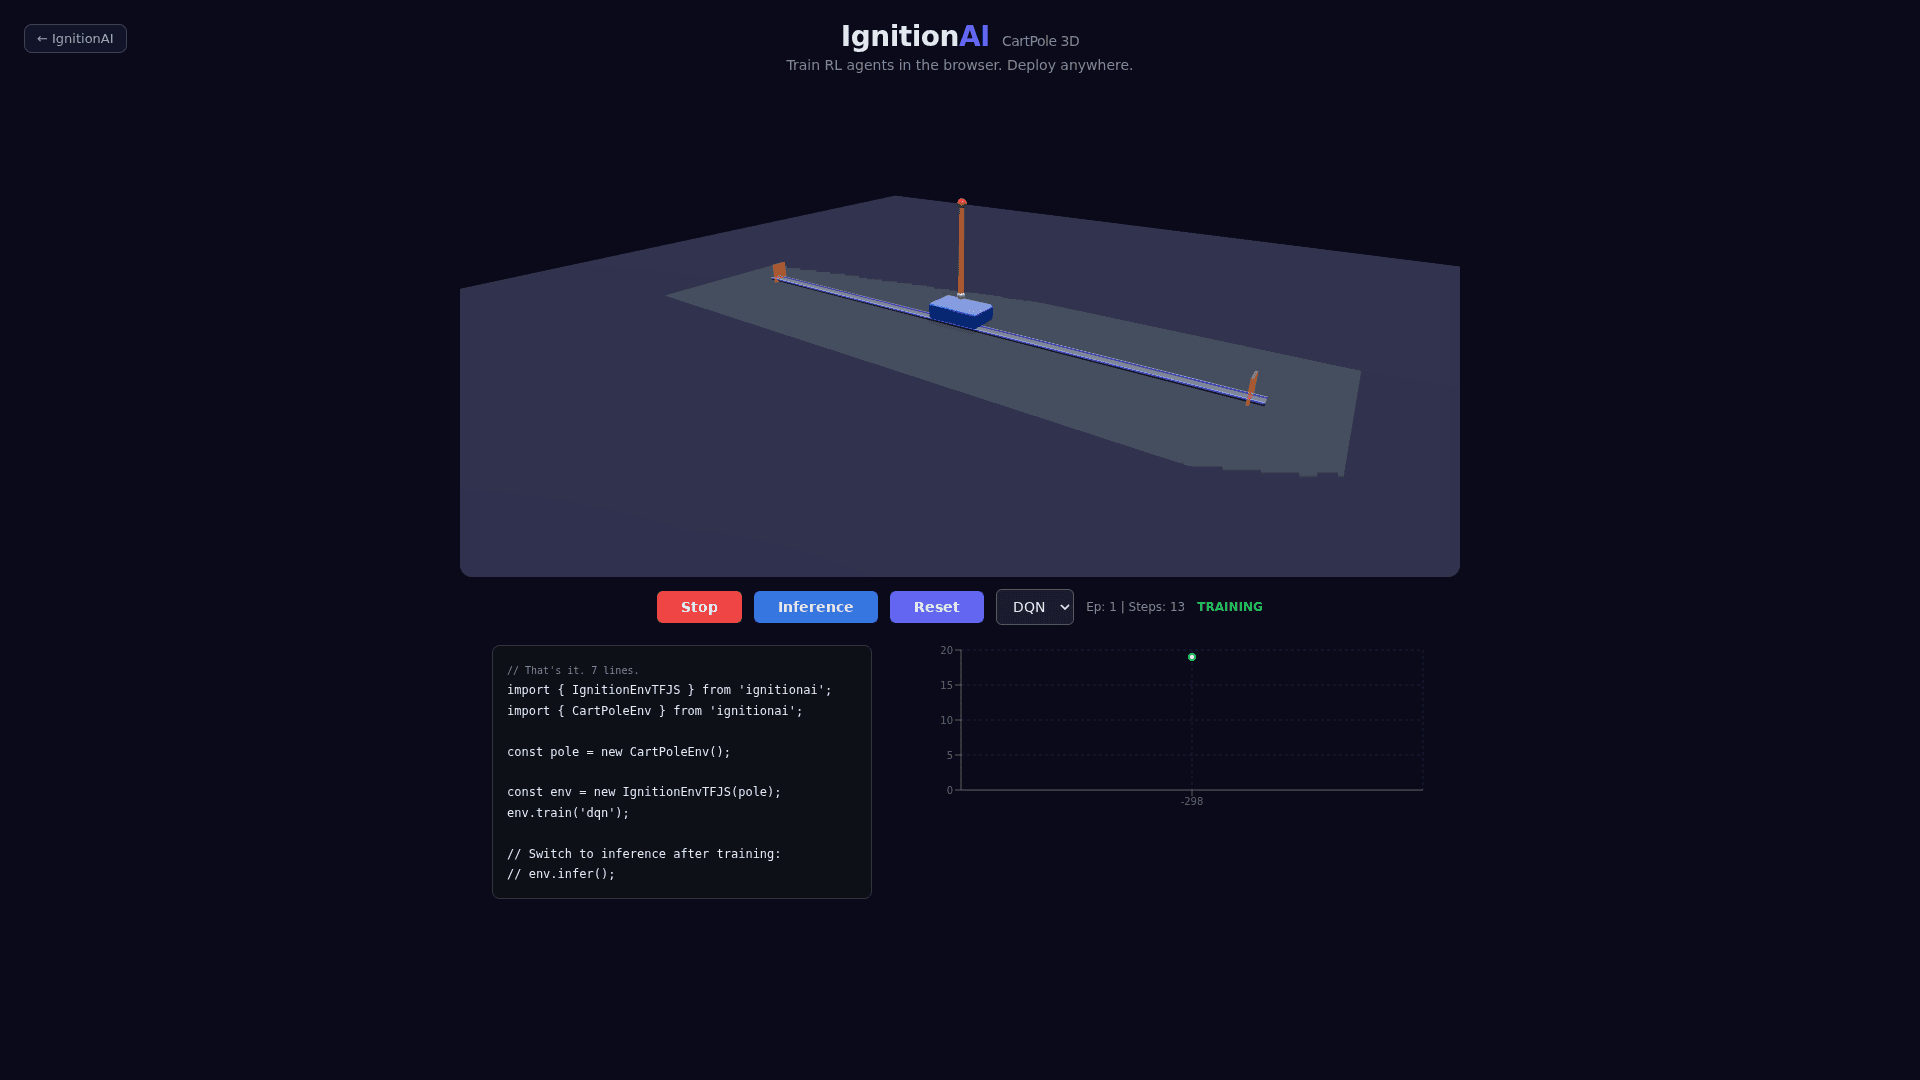
From raw state vector to agent decision in the 3D scene.
Read the tutorial →
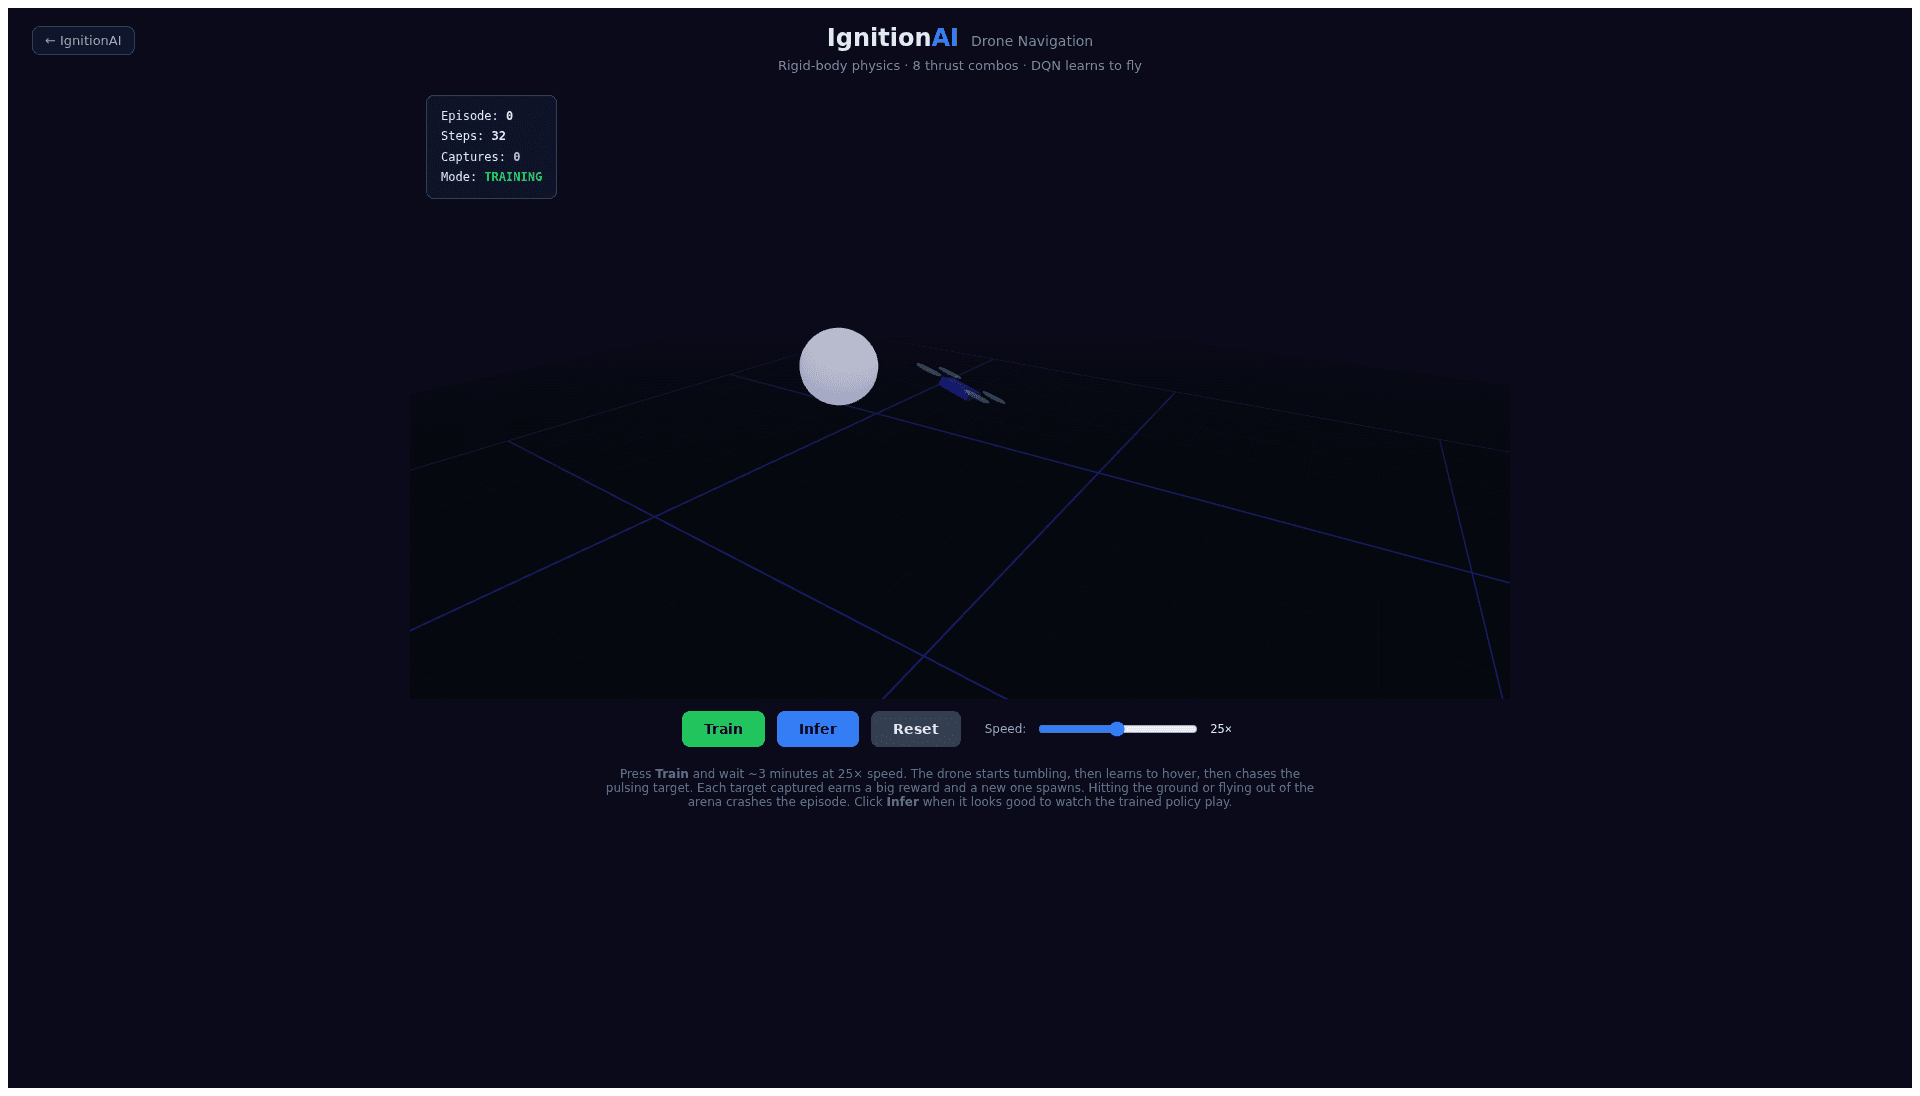
How the drone demo keeps flight stable while reaching its target.
Read the tutorial →
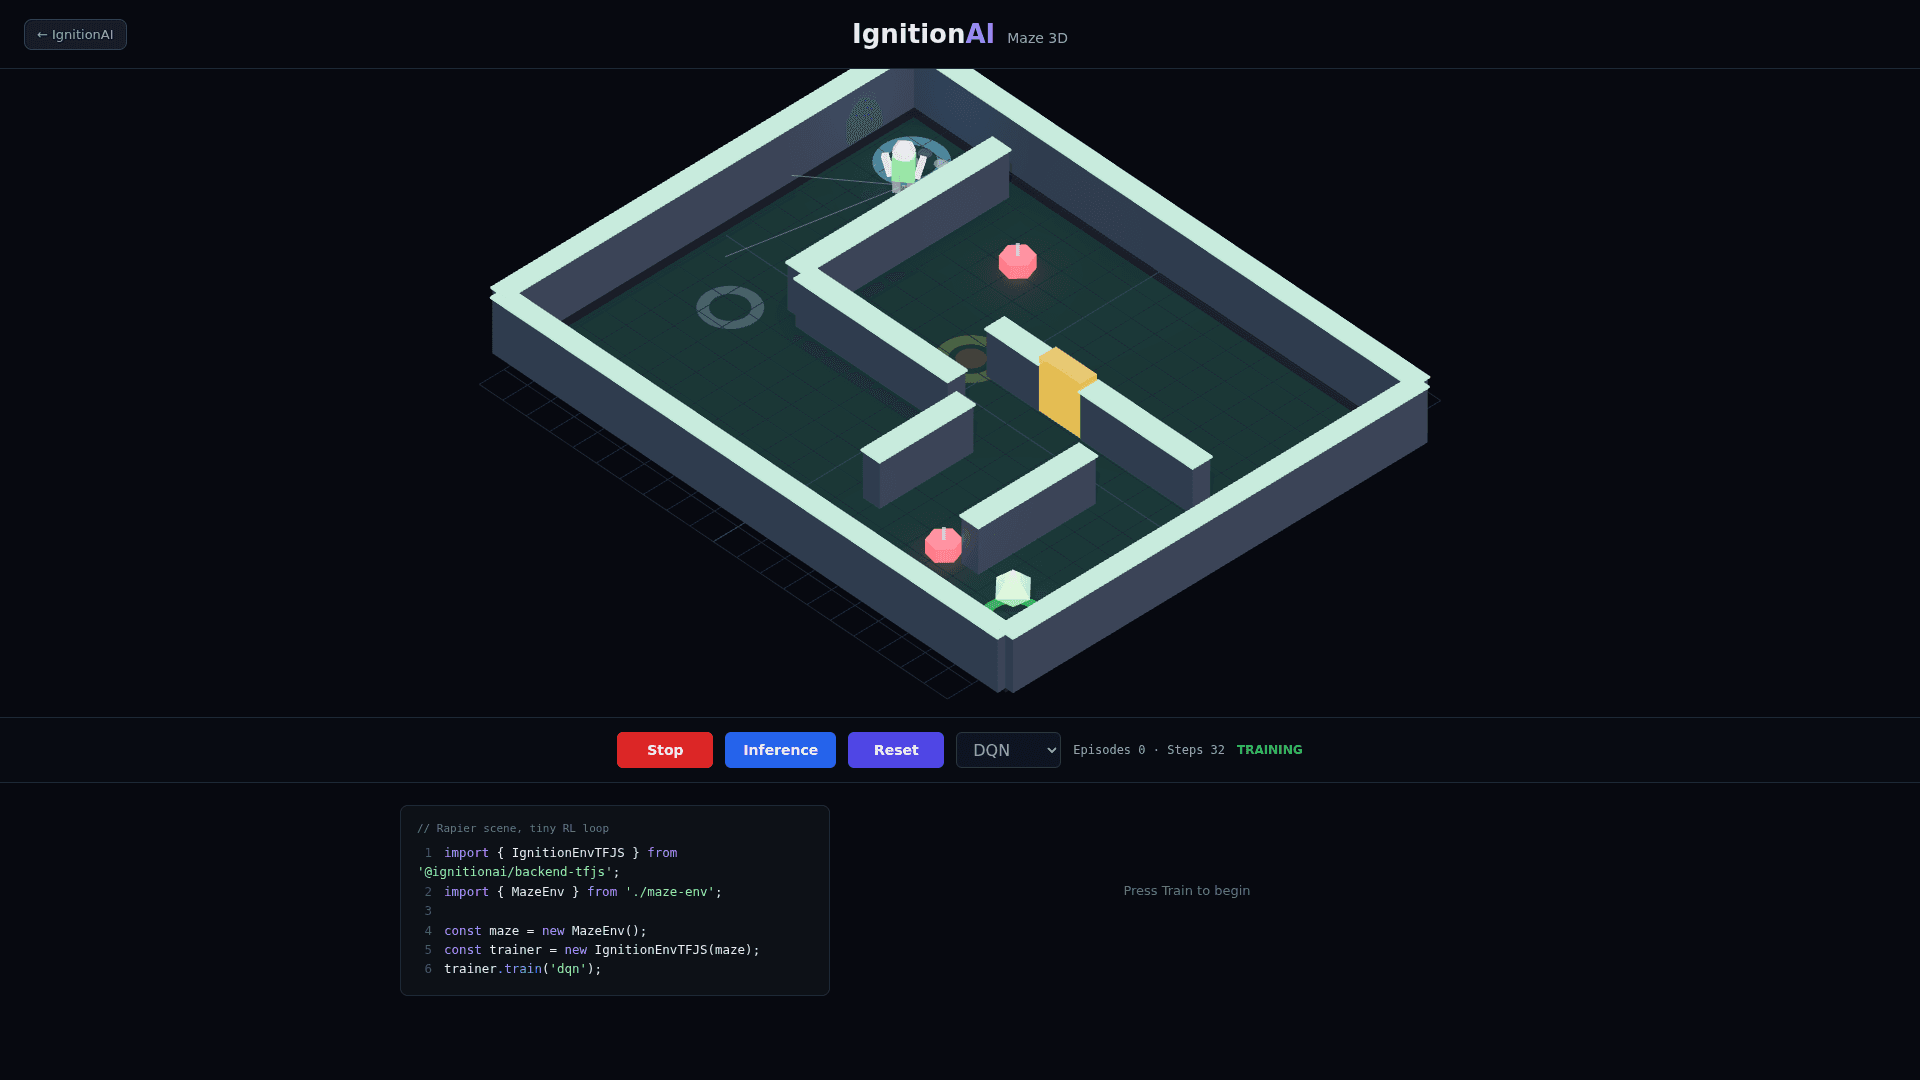
Dense rewards and sensors guiding the agent out of the maze.
Read the tutorial →
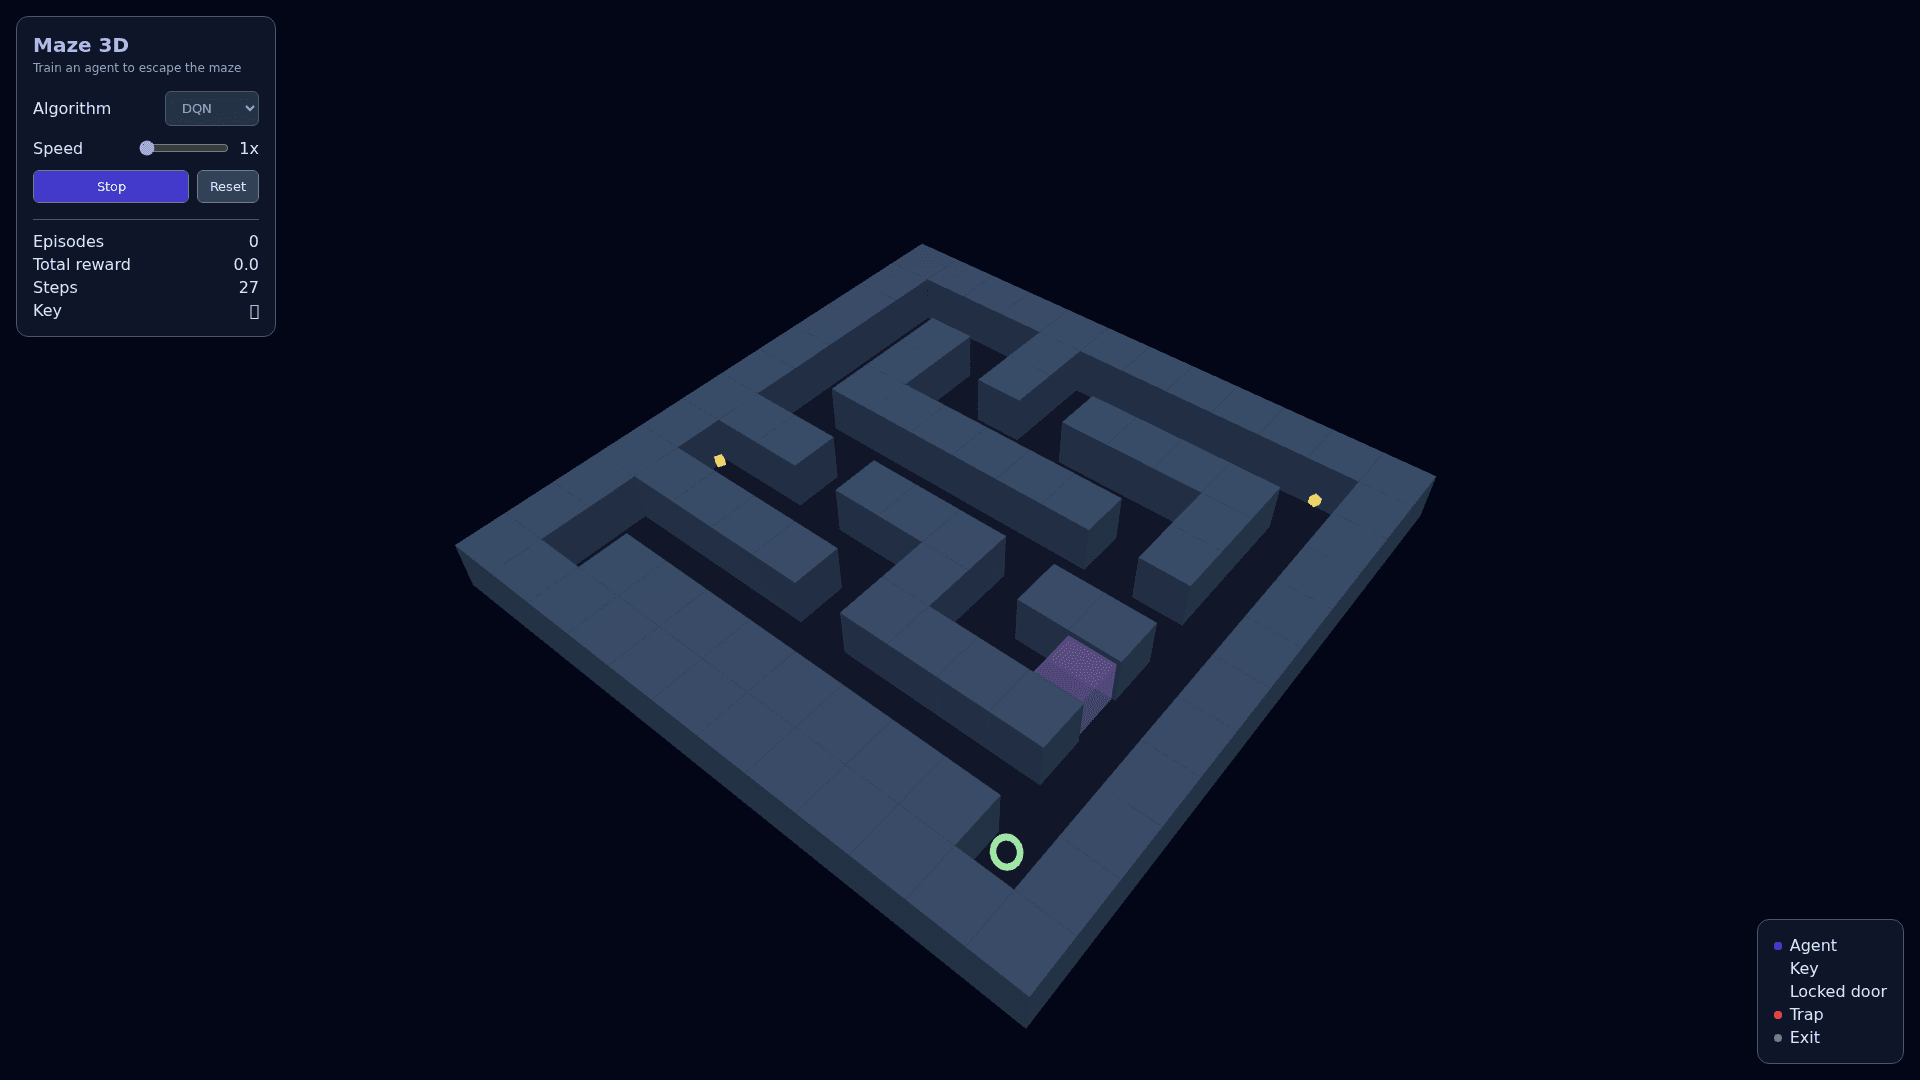
Exploration, keys and doors in a 3D maze.
Read the tutorial →
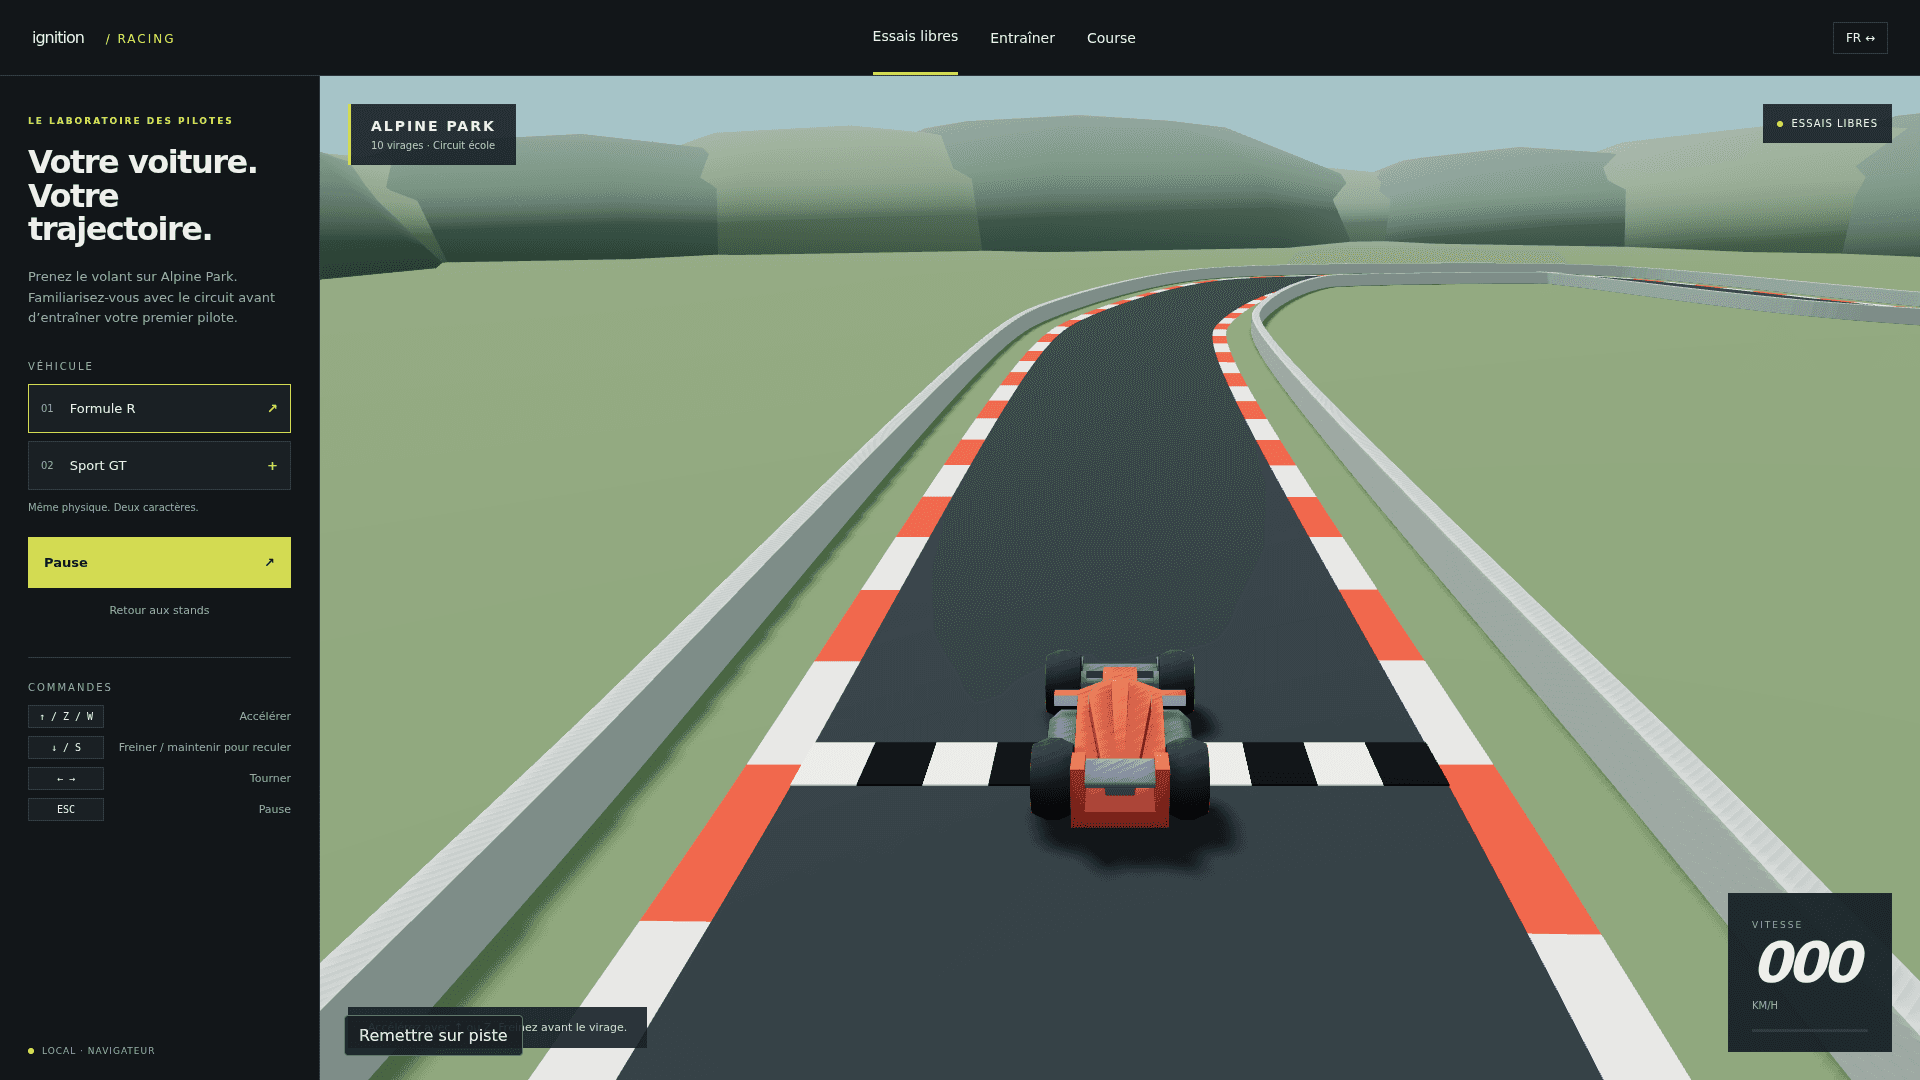
Teaching an agent to follow a track with dense rewards.
Read the tutorial →
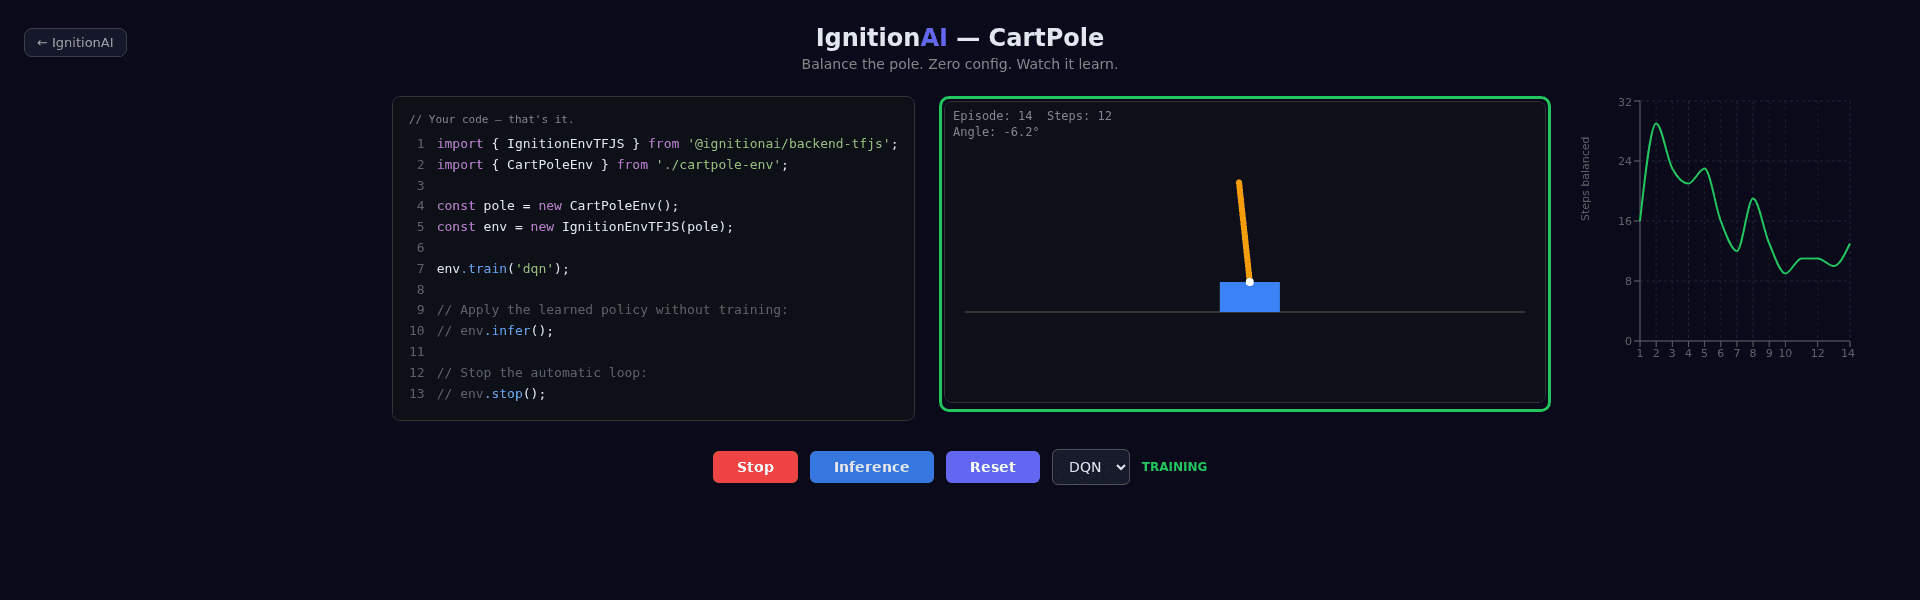
Run your first DQN training in the browser and watch its decisions on CartPole. Executable code and real screenshots included.
Read the tutorial →